

Quick answer: Industrial robot gripper maintenance tool box holds sway under 0.40 mm with 7.2 mm dividers and 4.5 Nm insert torque through a 2 h 10-55 Hz sweep.
Table of contents
- Divider thickness of the Industrial robot gripper maintenance tool box
- Insert tightening torque at the case bottom
- Divider sway after a two-hour frequency sweep
- Loosened points on the re-torque re-check
- Divider setting for the maintenance batch
- FAQ
1. Divider thickness of the Industrial robot gripper maintenance tool box
Sweeping from low to high, the shaker sets every compartment leaf in motion; one re-torque pass later, it is clear whether stock thickness or insert preload yielded first. Grid panels for the Industrial robot gripper maintenance tool box are milled from 7.2 mm sheet, joined by tongues so no leaf swings on its own. A thin panel hits resonance in the middle band and burnishes the slot edges, whereas a heavy one pulls down on the floor inserts.
| Panel class | Stock | Sway at first pass | Joint fit |
|---|---|---|---|
| Light | 6.4 mm | Wide | Slack |
| Nominal | 7.2 mm | Moderate | Close |
| Heavy | 8.0 mm | Narrow | Forced |
A 480x335x165 mm outline with a 420x280x115 mm cavity leaves 3.9 mm of wall, which caps the cell count. Two latches give 340 N each onto the lid, so panel loads arrive only through floor inserts. When the Industrial robot gripper maintenance tool box is checked for thickness, a leaf is lifted and its tongue wear band read; a bright streak means that section kept rubbing.
2. Insert tightening torque at the case bottom
No panel hangs free: its foot seats in a metal insert at the floor, tightened to 4.5 Nm. Two rows of such inserts carry the grid of the Industrial robot gripper maintenance tool box; at the specified preload a leaf and the floor move as one body.
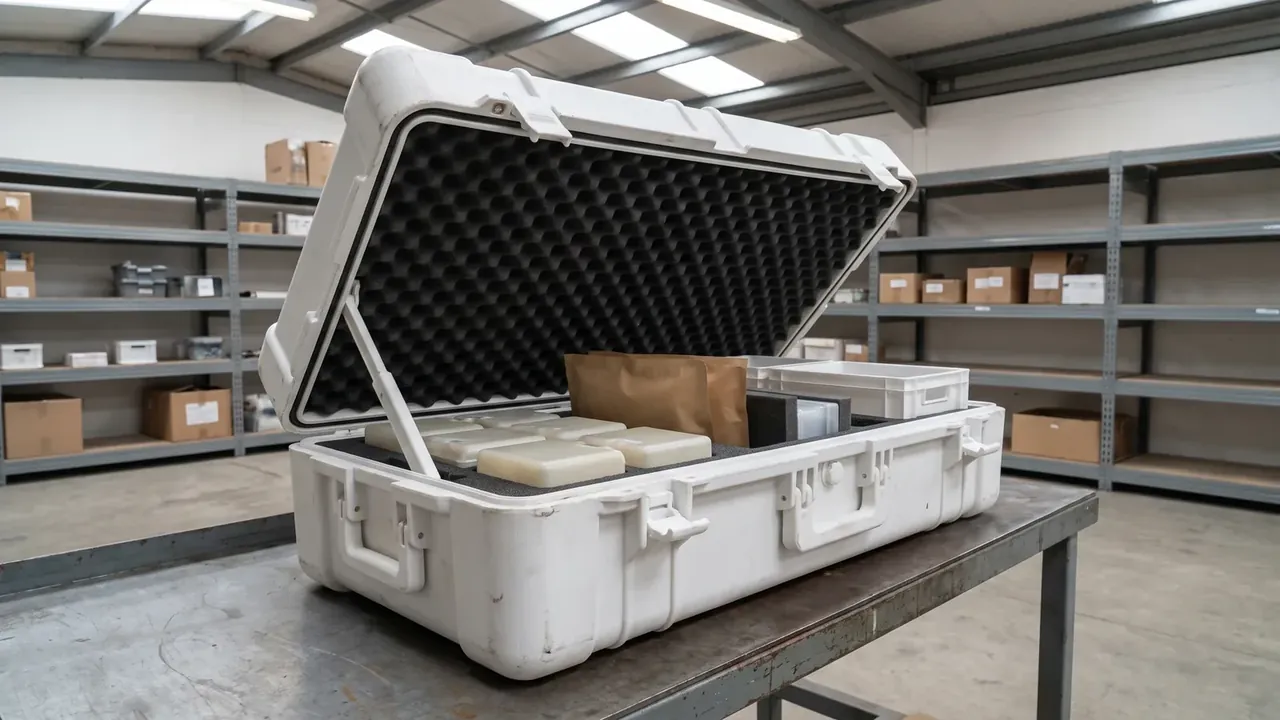
A 10 kg payload bends the floor further than an empty shell, and an insert set far from a support lengthens the lever acting on that 4.5 Nm value. The 4500 open-close count serves as a hinge-and-latch durability figure and also exposes fuzzed insert rims. Torque is printed beside each seat on the Industrial robot gripper maintenance tool box, and re-tightening uses a single calibrated driver instead of a wrist estimate.
3. Divider sway after a two-hour frequency sweep
The shaker applies a 10-55 Hz sweep for 2 h, and that is the complete mechanical history the shell sees. Low frequencies rock the whole enclosure, the middle range meets a panel's natural frequency, and the upper range worries the insert joints, so each stretch brings a different weak spot forward. Readings for the Industrial robot gripper maintenance tool box are taken once the second hour closes, never from a quiet opening minute.
| Sweep stage | Dial | Panel sway | Bench note |
|---|---|---|---|
| Opening | 10 Hz | 0.16 mm | Start log |
| Middle | resonance | 0.28 mm | Hold |
| Upper | 55 Hz | 0.34 mm | Hold |
| Repeat | full band | final figure | Grade and file |
A sway of 0.40 mm or less is the allowance left to the grid; beyond it the tongues have begun to rub and re-tightening no longer restores the fit. Sheet cut at 7.2 mm keeps the climb flatter, while light panels break out at mid-band. The Industrial robot gripper maintenance tool box is gauged after the shaker halts, so the value is a settled offset rather than a live tremor.
4. Loosened points on the re-torque re-check
Once the second hour ends, every insert is brought back to 4.5 Nm and the shell returns to the shaker for a second pass. The Industrial robot gripper maintenance tool box notes the angle each insert still turns, and every one that moves adds to the loosened count, with the acceptance line drawn at zero.
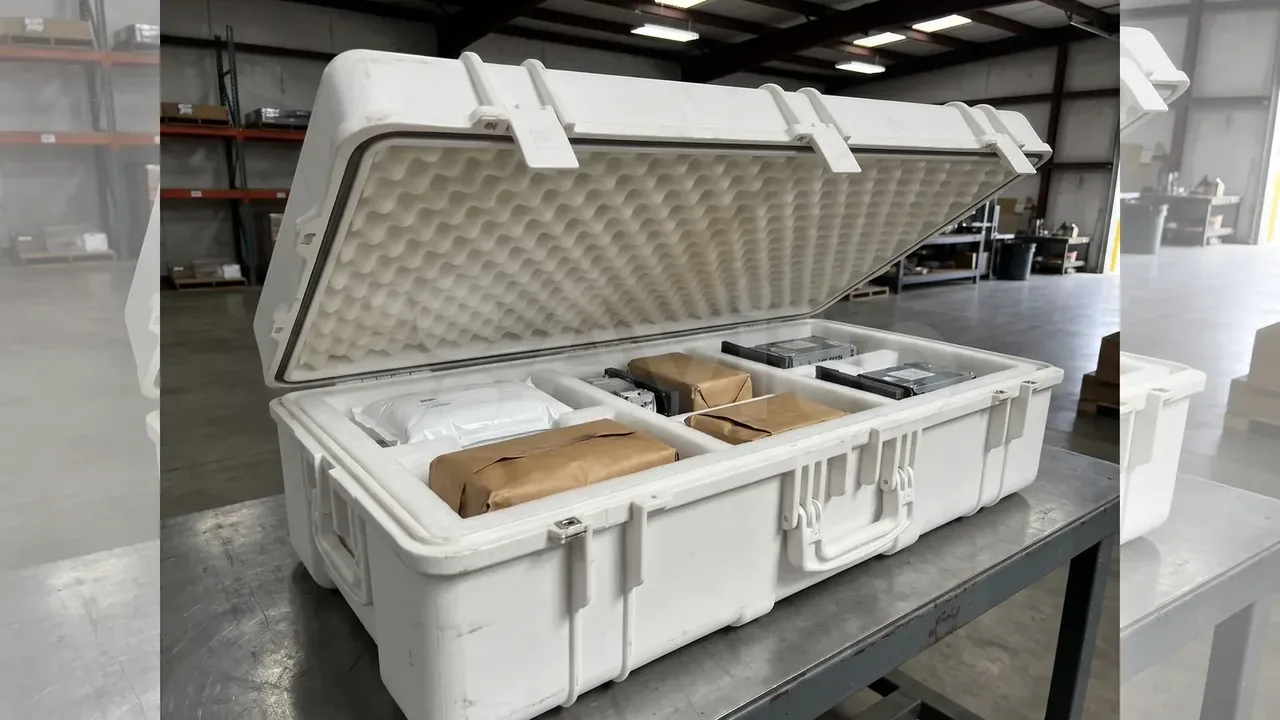
For that second pass the original parts stay in place: the swept shell, its own panels, no shims added, so the figure reflects stock and preload as fitted. A lone gasket squeezed 18% seals the mouth, which is a separate face from a loosened insert. On the Industrial robot gripper maintenance tool box the IP66-style bench sequence pairs sweep with spray; it describes a test order, not a certificate in hand.
5. Divider setting for the maintenance batch
Read the three tables side by side and a single stock value emerges for the maintenance batch of the Industrial robot gripper maintenance tool box: the thinnest class whose sway at hour two still sits below 0.40 mm, with lighter panels dropped from the build sheet. A light leaf keeps the lever arm short, so 4.5 Nm needs no increase and 340 N per latch still holds.
| Sway reading | Batch call | Follow-up |
|---|---|---|
| up to 0.40 mm | Release | Loosened count |
| 0.40 to 0.60 mm | Quarantine | Tongue wear |
| over 0.40 mm | Reject | Insert rim |
That value is released together with 4.5 Nm preload and 18% squeeze, and editing any of the three puts the Industrial robot gripper maintenance tool box through the whole 2 h again instead of reusing figures from another band. The build sheet carries nothing beyond the listed rows, and light panels are filed as samples.
Conclusion
Rigidity in the grid of an Industrial robot gripper maintenance tool box is governed less by one stiff leaf than by pairing 7.2 mm stock with 4.5 Nm preload at the shell level. A 2 h sweep exposes sway and loosened seats in one run, the hour-two figure settles the batch, and a re-tightening pass verifies zero movement. The build sheet is signed off by JUNZHIJIA with that value fixed, so no panel is swapped at the last minute; tracking the grid and its seats beats tallying what fills the cells.
Related Reading
- Cobot Teach Pendant Cases: Pendant & Controller Protection
- Collaborative Robot Transport Cases: Protection for Arms & Teaching Pendants
- EPE Foam vs EVA Foam in a Tool Box: What Is the Difference?
- Rust on a Metal Toolbox: How to Remove It and How to Stop It Coming Back
Related Products
- 8 Series — Gun Cases; Military Equipment Cases; Camera Equipment Cases; Drone Cases; Watch Cases; Knife Cases; First Aid Cases; Electronics Equipment Cases
- WL8-2812 PP Gun Case — model WL8-2812
- All protective cases and toolboxes: 7 series, 158 models