

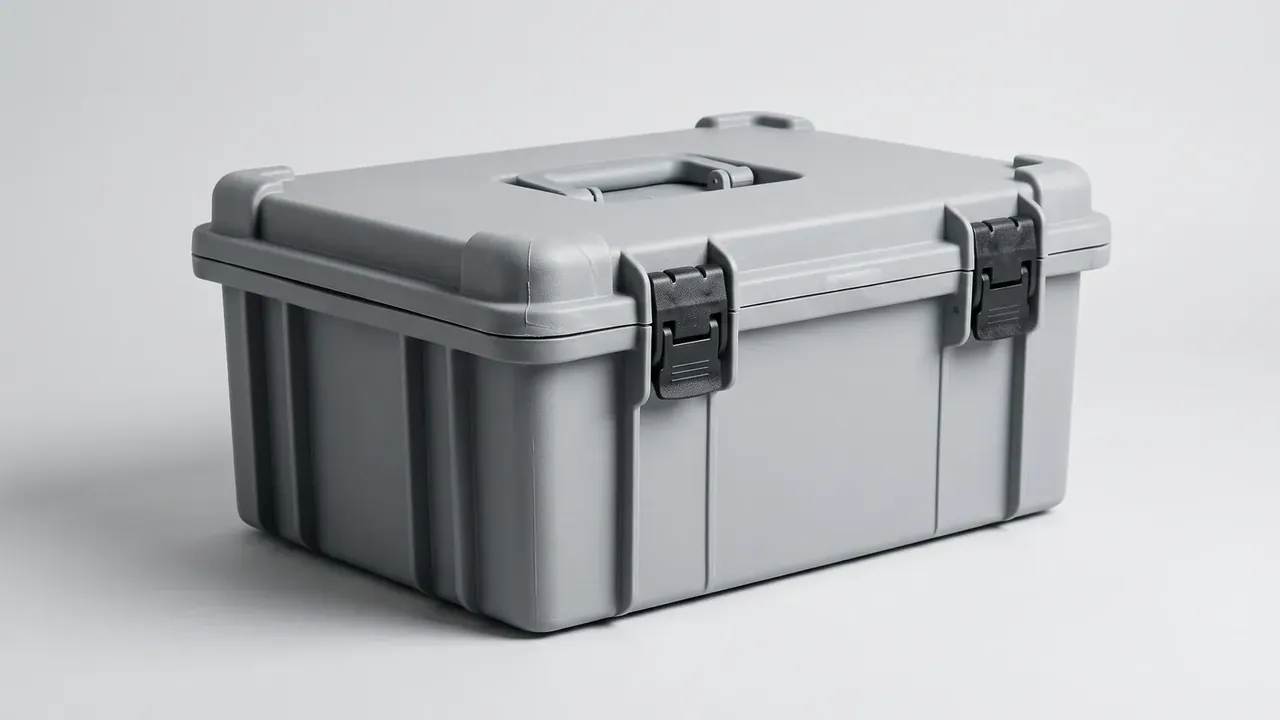
Quick answer: A Robot Accessories Transport Case carries two 780 mm linear rails on three end supports, with four 350 N straps holding deflection at 0.6 mm/m.
Table of contents
- Long-axis fixing in a Robot Accessories Transport Case
- Preload split across four straps
- Deflection of 0.6 mm per metre
- Positions of the three end supports
- Fixing setting for an accessory batch
- FAQ
1. Long-axis fixing in a Robot Accessories Transport Case
Long-axis parts ask a different question than fit: whether the unsupported length at each end will bow on its own. A Robot Accessories Transport Case measures 900 by 400 by 320 mm outside behind a 5.0 mm wall, leaving 840 by 340 by 270 mm inside. Two linear rails of 780 mm sit in that cavity with 30 mm spare at each end, and rails take most of the 28 kg load. The longer the rail, the sooner road shock presses a curve into the mid-span, and every support left out adds a curved segment.
Clamping runs through axial pressure plates rather than foam. Each plate presses 40 mm of the rail end across its width over a 2 mm resilient pad, with no gap left. A Robot Accessories Transport Case logs plate position by end setback, 20 mm at each end and 370 mm for the centre point.
| Fixing layout | Supports | Support footprint | Deflection |
|---|---|---|---|
| One at each end | 2 points | 40 mm | 1.1 mm/m |
| Three end supports | 3 points | 60 mm | 0.6 mm/m |
| Four end supports | 4 points | 80 mm | 0.45 mm/m |
Two supports alone leave the 780 mm span on two points, reading 1.1 mm/m against a 1.0 mm/m reject line. Four supports press it to 0.45 mm/m but take 80 mm of mounting room off the rail ends. Three supports land at 0.6 mm/m on a 60 mm footprint, the compromise between length and stiffness.
2. Preload split across four straps
Straps work across, plates work along, and neither replaces the other. Four straps on a Robot Accessories Transport Case preload at 350 N each across the 340 mm cavity width, over a 3 mm wear pad. Equal preload does not mean equal share: the end strap sits near a support and its force reaches the plate directly, while the middle straps push across 300 mm or more.
A Robot Accessories Transport Case records strap position by distance from the end, at 60 mm, 300 mm, 480 mm and 720 mm. Shift a strap and the share changes with it, which puts the deflection reading out of step with the ledger.
| Strap | Distance from end | Preload | Share |
|---|---|---|---|
| First | 60 mm | 350 N | 34% |
| Second | 300 mm | 350 N | 22% |
| Third | 480 mm | 350 N | 22% |
| Fourth | 720 mm | 350 N | 22% |
The two end straps carry 34% each and the middle pair 22% each. Let one strap fall to 300 N and that middle share slides toward the ends, raising local load on the plate until the rail face takes a mark. Straps are therefore measured and logged one by one, never averaged across a batch.
3. Deflection of 0.6 mm per metre
Reporting deflection per metre lets parts of different lengths share one table. At 0.6 mm/m a 780 mm rail sags 0.47 mm at mid-span, while the same grade on a 1.2 m part gives 0.72 mm. A Robot Accessories Transport Case reads deflection free-standing: straps released, plates released, the part resting on three supports only.
A Robot Accessories Transport Case takes the reading with a taut line and a dial gauge: a 0.2 mm line runs along the rail side, both ends on the support faces, and the gauge reads mid-span plus both quarter points, keeping the largest figure per metre.
| Preload grade | Deflection | Sag over 780 mm |
|---|---|---|
| One looser | 0.8 mm/m | 0.62 mm |
| Nominal | 0.6 mm/m | 0.47 mm |
| One tighter | 0.5 mm/m | 0.39 mm |
At 0.62 mm the sag is visible and the rail needs straightening back on the machine; at 0.5 mm the figure looks good while straps pull 400 N for months and shorten buckle and pad life. The reject line is 1.0 mm/m.
4. Positions of the three end supports
Three supports are not evenly divided. The two end points set back 20 mm each to shorten the cantilever, and the centre one sits at 370 mm, dead centre of the 780 mm span. A longer cantilever tips the rail end further, and the mounting holes no longer line up with the machine.
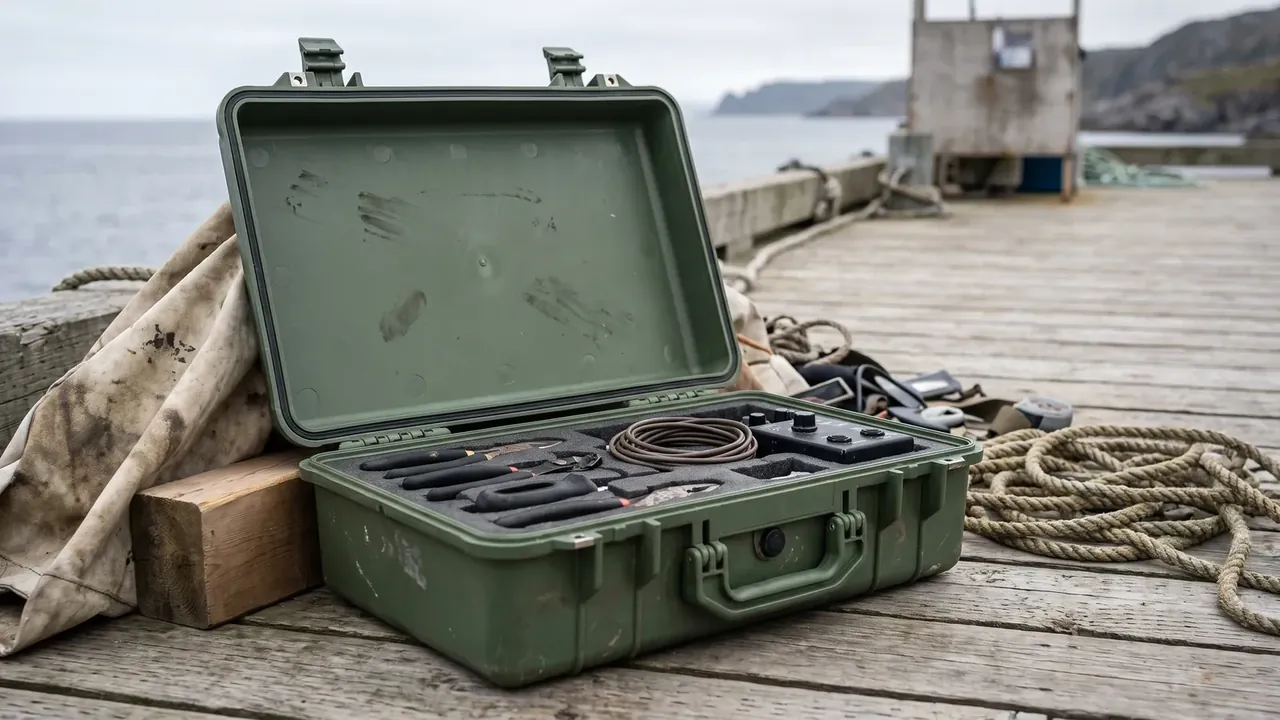
Each support uses a 40 mm axial plate over a 2 mm pad, its screws tightened diagonally in two passes at 6 N·m, since a single pass crushes the pad. End plates clear the rail mounting holes by 15 mm, and the pad measures about 1.6 mm once compacted: a thick pad leaves the support soft, a thin one puts the plate on bare plastic.
Shift the centre support past 5 mm and the two cantilevers end up unequal, pulling the reading toward the long side. A Robot Accessories Transport Case checks each support-to-end distance and logs the three values on one line.
5. Fixing setting for an accessory batch
Two lines close a batch: deflection at 0.6 mm/m or under, and support and strap positions within 5 mm. The fewest supports and lowest preload inside both lines become the setting; extra supports or preload send the batch back.
Boundary conditions lock in together: a 28 kg load, 3 h of vibration, a 0.9 m drop, four straps at 350 N and three supports. Deflection is read after the vibration run, the drop lands once on a corner and once on an end face, and the supports are rechecked for movement afterwards. A new support mould restarts both the vibration and the drop benches.
A Robot Accessories Transport Case runs sheets per shell: three support positions, four strap shares, deflection, post-vibration check and post-drop check. Five entries make the grade, and one missing entry pulls that shell alone.
Conclusion
A Robot Accessories Transport Case holds its long-axis parts with three supports and four straps working together: a 780 mm rail sags only 0.47 mm at 0.6 mm/m, leaving 0.4 mm/m of room to the reject line. A fourth support buys another 0.15 mm/m but spends 20 mm of length, which is a poor trade. JUNZHIJIA files the 3 h vibration and 0.9 m drop records by batch, and drawing tolerances are issued by Kexin New Materials (Guangdong) Co., Ltd.
Related Reading
- Industrial robot arm case: supporting joints and arm links in transit
- Collaborative robot transport case: fixing a light frame
- Dispensing robot case: moving feed and motion parts
- Plastic case or carton: two routes for e-commerce turnover
Related Products
- 8 Series — Gun Cases; Military Equipment Cases; Camera Equipment Cases; Drone Cases; Watch Cases; Knife Cases; First Aid Cases; Electronics Equipment Cases
- WL8-2812 PP Gun Case — model WL8-2812
- All protective cases and toolboxes: 7 series, 158 models